How to update the joint firmware?
Download
- Windows: xarm-tool-gui-2.19.8
- Linux:xarm-tool-gui-linux-2.19.8
How to check the joint firmware version?
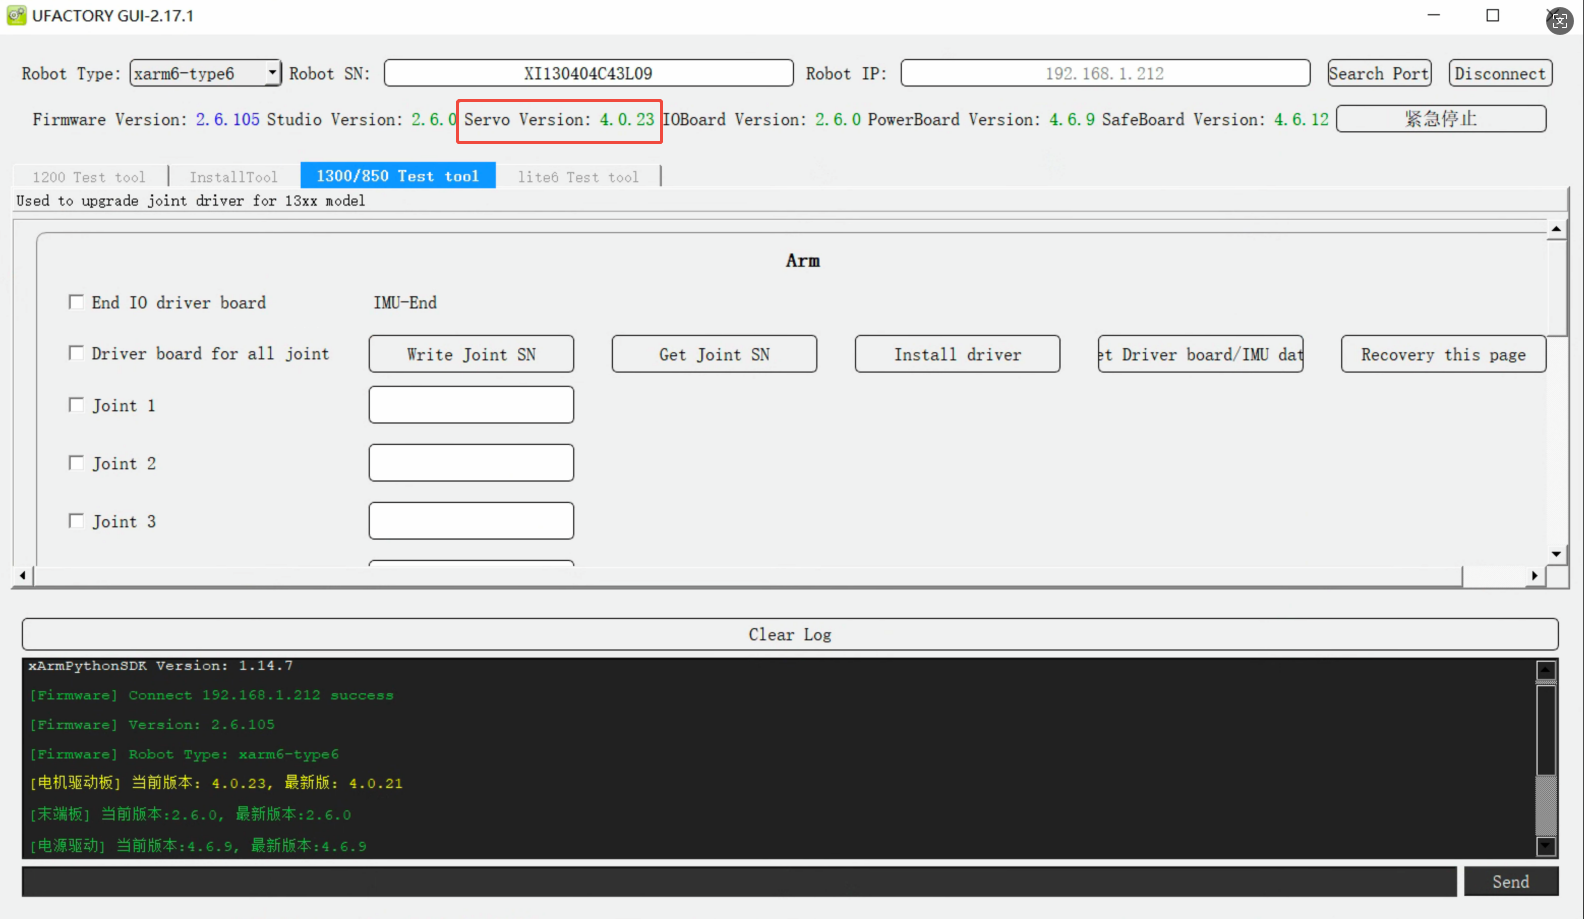
Launch xarm-tool-gui, enter the Robot IP and click Connect. As shown in the figure below, the servo(joint) version is V4.0.23.
Mapping of joint firmware to robot
| Robot Arm Model | Servo Firmware File | Version Number | Latest Version |
|---|---|---|---|
| xArm1303 or lower version | uf_servo_stm32f4xx_app_2.7.13.bin | V2.7.x | V2.7.13 |
| xArm1304 or Lite6 | ServoGD32F405App_V4.0.23_debug_20250317.bin | V4.0.x | V4.0.23 |
| xArm1305 or 850 | ServoGD32F425App_V5.0.14_debug_20251128.bin | V5.0.x | V5.0.14 |
NOTE
Upgrading between major versions is not supported (e.g., upgrading from V4.x to V5.x).
How to update the joint firmware?
- Connect with xarm-tool-gui.
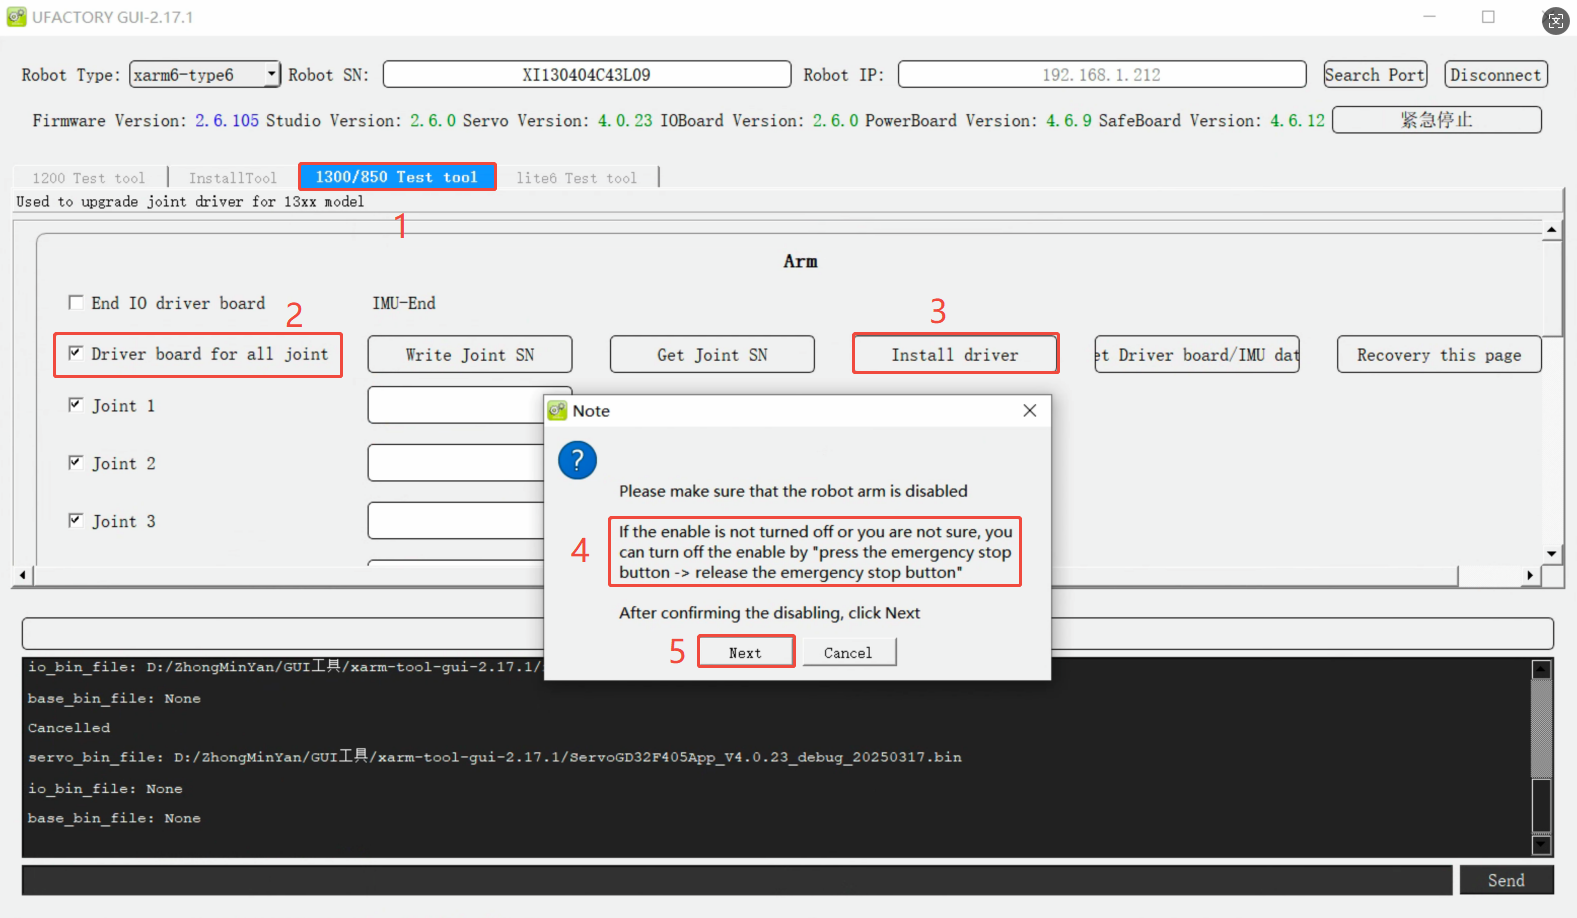
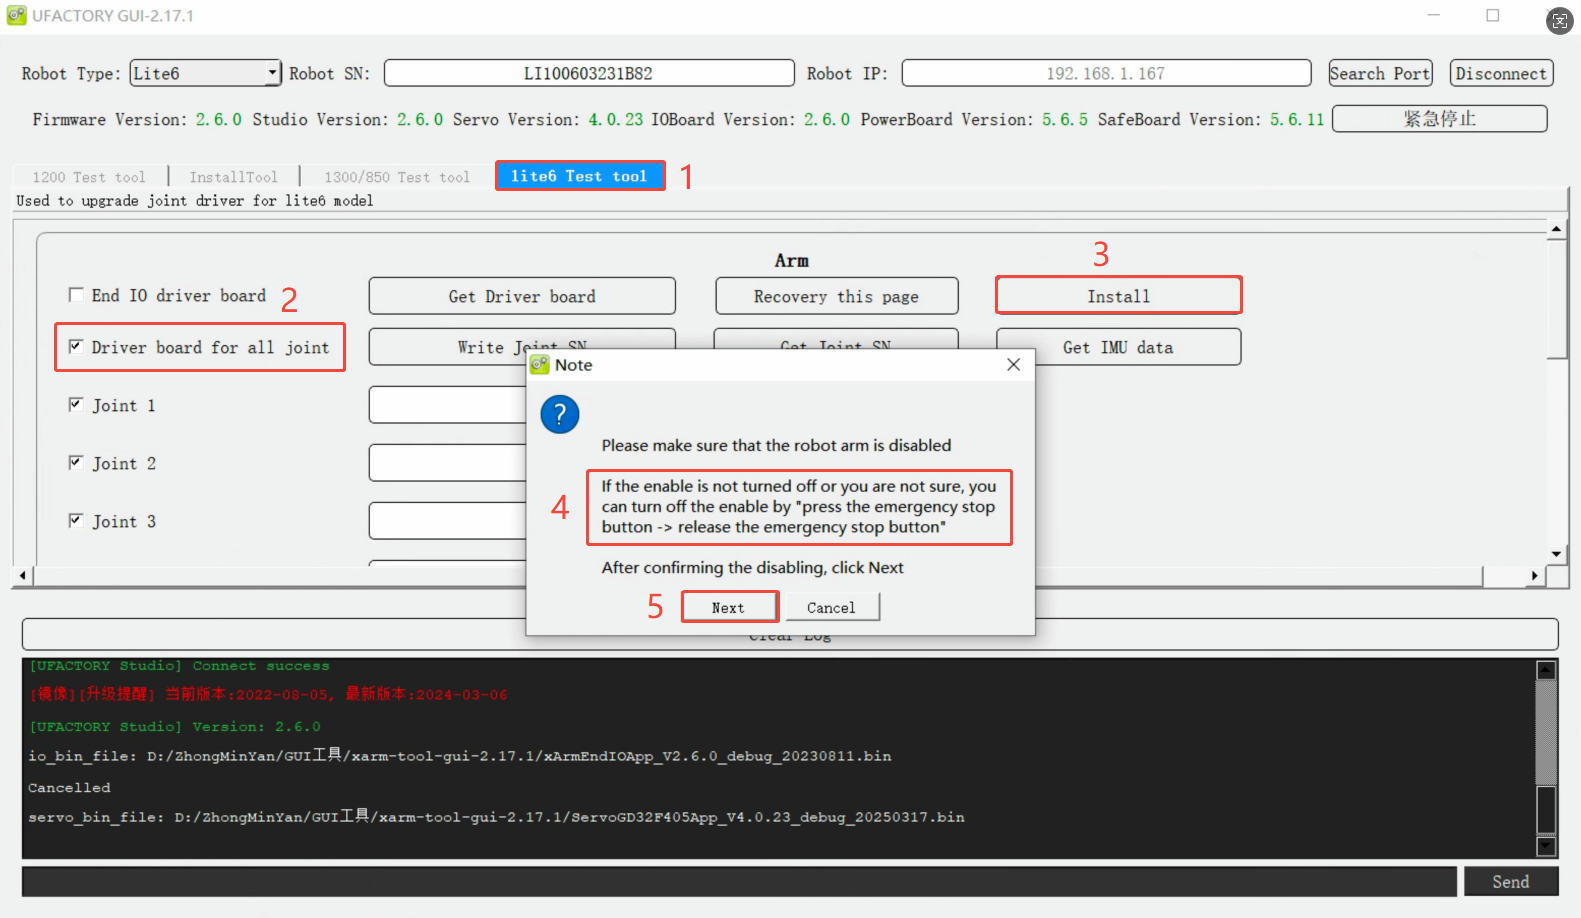
- Switch to the corresponding test tool, choose driver board for all joints,click install driver, choose the corresponding bin file. Press down the Emergency stop button and release, click Next.
- 1305 or 850: 1300/850 Test tool
- Lite6: Lite6 Test tool
- xArm12xx or lower version: 1200 Test tool
- Wait for 2-3 minutes, it will prompt 'Installation Success'. The arm will reboot automatically. Wait for 1-2 minutes, re-connect with xarm-tool-gui, enable the robot, and check the joint firmware version.